 中文
Tiny and Precise
Outer diameter: 80mm
Length: 64.2mm
Weight: 1.03kg
Max. Torque: 143N.m
Max. Speed: 60RPM
Working Principle of the Robotic Joint Module
Upper-level commands drive the motor via the bus, and the power is amplified and output through the reducer. Meanwhile, the dual encoders and torque sensor provide real-time status feedback. The driver dynamically compensates for errors through full closed-loop control, ultimately achieving precise and fast robotic joint motion.
Structure of our eRob series Robot Joint Actuator
The eRob series robotic joint module is a highly integrated all-in-one solution that combines eight core components: a servo motor, high-precision harmonic gear reducer, dual absolute encoders, servo drive, friction brake, temperature sensor, and virtual torque sensor. This innovative design eliminates the need for complex external component selection and integration, providing users with a plug-and-play power unit that significantly simplifies the robotics development process. It is an ideal choice for building high-performance collaborative and humanoid robots.
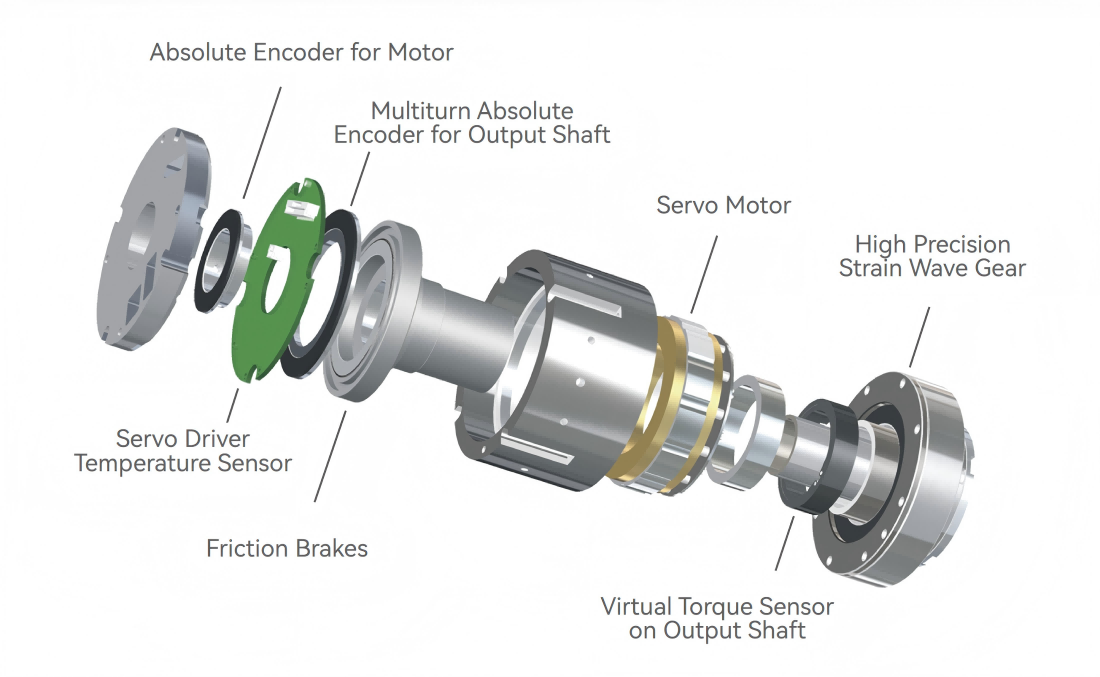
The eRob80 robotic joint module delivers a high 143N·m torque in a compact, through-hole design (Ø80mm, 1.03kg). Ideal for humanoid, bionic, and collaborative robots requiring power and precision.
Integrated Structural Design Features
• High Integration: Precision integration of all components into a compact housing (e.g., eRob70F: OD 70mm, length 67.7mm), greatly simplifying robot design and assembly.
• Compact & Lightweight: Patented "nested encoder disc" design reduces volume and weight while improving torque density.
• Center Through-Hole: An 18mm diameter central hole allows cable routing, resulting in a cleaner robot appearance.
• Modular Interfaces: Supports EtherCAT, CANopen, and STO (Safe Torque Off), enabling plug-and-play integration.
Built-in Servo Driver & Communication Protocols
With EtherCAT, CANopen, Modbus communication protocols.
Position, Speed, Current loop PID adjustable in real-time.
Built-in ±10V analog input.
Pulse and direction, I/O, RS485.
External encoder and STO interface.

Built-in Dual Absolute Encoder – Dual Loop Position Control
19bit absolute multiturn encoder for output shaft.
Repeatability up to ±7 arc seconds.
Absolute accuracy up to ±15 arc seconds.
Always have real absolute position and multi-turn counter when power-off.

Friction Brake Inside
Brake smooth and stable.
No gap; no backlash.
No need to move when power-on.
No wear and tear.
Can be used as Emergency Stop.

| Model | eRob80H (V5) | eRob80H (V6) | |||||||
| Strain wave gear-ratio | 17-50 | 17-80 | 17-100 | 17-120 | 17-50 | 17-80 | 17-100 | 17-120 | |
| Peak torque for start and stop(Nm) | 44 | 56 | 70 | 70 | 44 | 56 | 70 | 70 | |
| Permissible max.value at average load torque(Nm) | 34 | 35 | 51 | 51 | 34 | 35 | 51 | 51 | |
| Rated torque(Nm) | 21 | 29 | 31 | 31 | 21 | 29 | 31 | 31 | |
| Permissible maximum momentary torque(Nm) | 91 | 113 | 143 | 112 | 91 | 113 | 143 | 112 | |
| Max. output rotational speed(RPM) | 60 | 37.5 | 30 | 25 | 60 | 37.5 | 30 | 25 | |
| Motor power(W) | 146 | 126 | |||||||
| Without Brake | SWG Input Side Inertia (g∙mm²) | 67408 | 41815 | ||||||
| Outer diameter*length(mm) | 80x84.2 | 80x64.2 | |||||||
| Weight(KG) | 1.19 | 1.03 | |||||||
| With Brake | SWG Input Side Inertia (g∙mm²) | 70637 | 44961 | ||||||
| Outer diameter*length(mm) | 80x84.2 | 80x64.2 | |||||||
| Weight (KG) | 1.25 | 1.09 | |||||||
| Common parameters | ID:18mm, IP grating:IP54, Brake model:friction brake | ||||||||
| Optional device | Communication type:EtherCAT/CANopen/Modbus; Output encoder resolution:19Bit,Repeatability/Accuracy:±7/±15 arc seconds or ±10/±25 arc seconds. | ||||||||